Robotics · Embedded Systems
ENES100 On-Terrain Vehicle
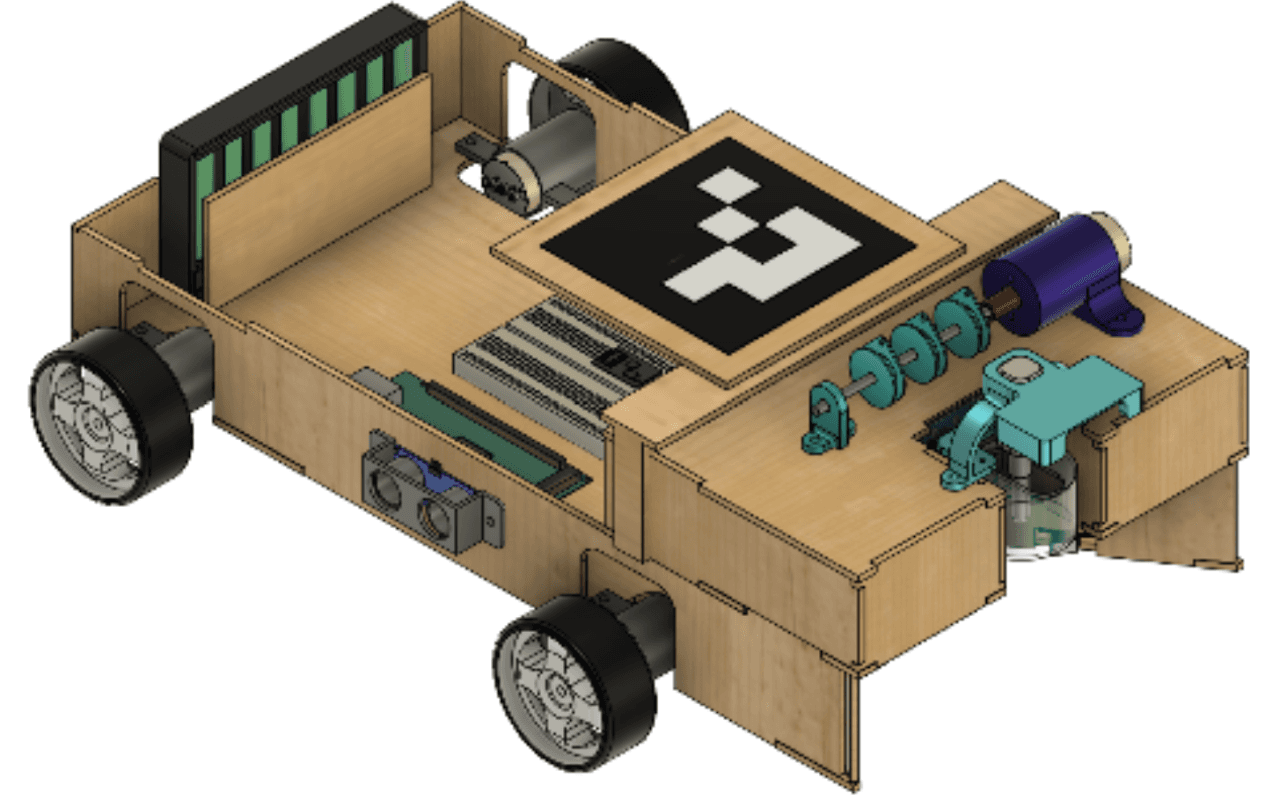
1 / 20
Video
Overview
The ENES100 On-Terrain Vehicle (OTV) project involved designing and implementing a vehicle capable of collecting a water sample and identifying pollutant content.
After collecting the sample, the vehicle was required to autonomously traverse a designated course while avoiding three obstacles. The vehicle then had to pass underneath a bar before reaching the end of the course.
The project combined mechanical design, embedded systems, sensing, and autonomous vehicle operation into a single engineering system.
Design Approach
Water Sampling & Pollutant Detection
- —Designed the vehicle to collect a water sample as part of the mission requirements
- —Implemented a method for identifying pollutant content in the collected sample
- —Integrated the sampling and detection requirements into the overall vehicle design
Vehicle Navigation
- —Designed the vehicle to traverse the designated course
- —Implemented obstacle avoidance for three obstacles along the course
- —Designed the vehicle to successfully pass underneath a bar before reaching the end of the course
System Integration
- —Integrated the vehicle's mechanical, electrical, sensing, and control systems
- —Designed the system around the combined requirements of sampling, pollutant identification, navigation, obstacle avoidance, and course completion
Simulation & Testing
The completed vehicle was tested against the requirements of the ENES100 course, including water sampling, pollutant identification, obstacle avoidance, and navigation through the final low-clearance section.
Testing focused on the vehicle's ability to complete the required sequence of tasks and successfully reach the end of the course.
Key Features
- —On-terrain autonomous vehicle
- —Water sample collection
- —Pollutant identification
- —Course navigation
- —Three-obstacle avoidance
- —Low-clearance bar traversal
- —Embedded systems integration
- —Mechanical and electrical system integration
- Embedded Systems
- Obstacle Avoidance
- Sensors
- Vehicle Design
- System Integration